

Autonomous Driving
With this project, we aim to further the development and research of Artificial Intelligence within our educational institution and, of course, contribute to the advancement of new technologies in our country. We have begun to investigate and develop algorithms for autonomous driving's localization, perception, and planning.
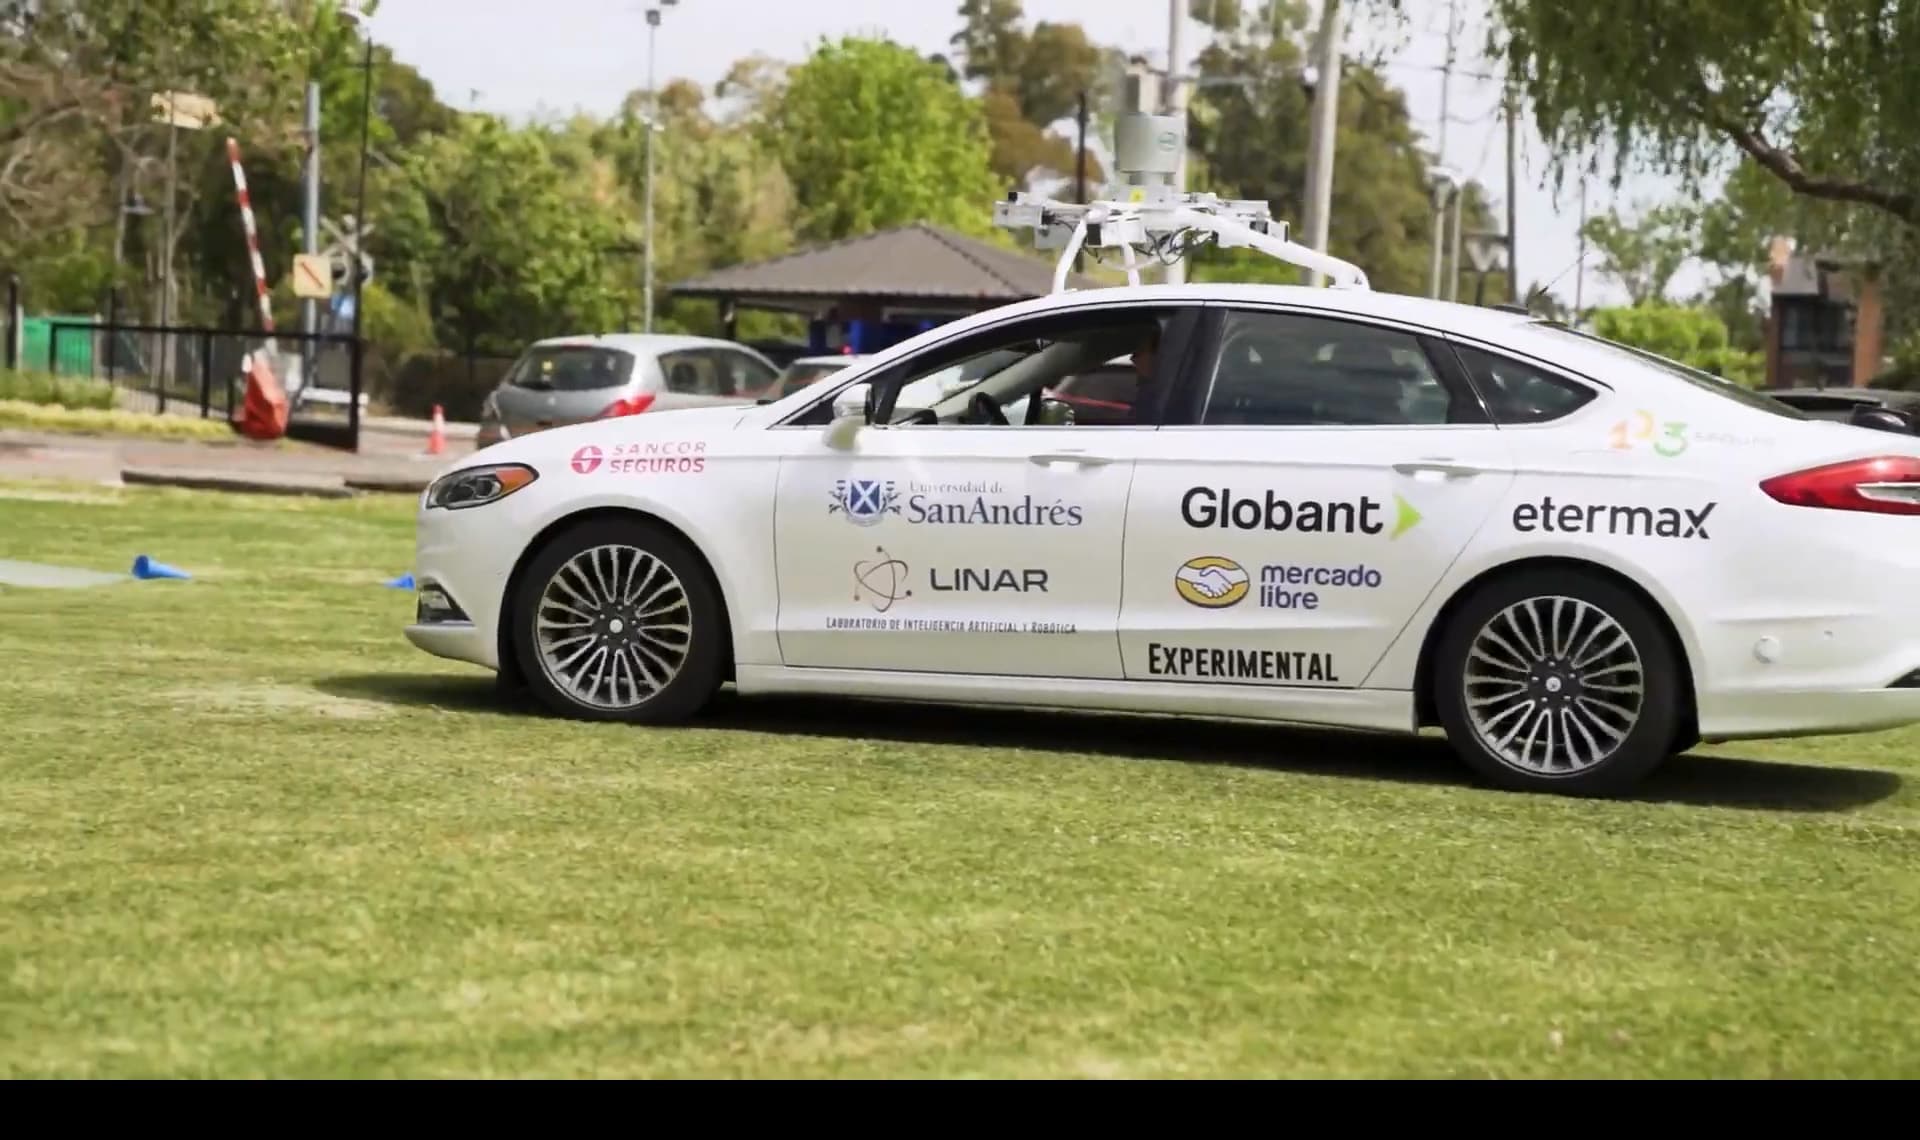
The vehicle is a 2017 Ford Fusion Hybrid equipped with a drive-by-wire system that enables computer-controlled commands for all aspects of the car. It features a range of sensors (lidar, cameras, radars, GPS, computer) that allow it to perceive the environment and navigate through integrated computer systems.

Work has commenced on the vehicle integration process, involving calibrating and testing various sensors, as well as developing algorithms for localization, perception, control, and planning.
In the short term, our goal is to create a dataset of a city like Buenos Aires. What does this mean? It involves driving manually while collecting data from cameras, LiDAR, and GPS location, and then making this data available for other research teams to use in training their own algorithms.
